Appendix CUseful Facts and Formulas
## C.1 Greek Alphabet
| Alpha | A | a | Eta | E | h | Nu | N | n | Tau | T | t |
|---|---|---|---|---|---|---|---|---|---|---|---|
| Beta | B | b | Theta | Q | q | Xi | X | x | Upsilon | U | u |
| Gamma | G | g | Iota | I | i | Omicron | O | o | Phi | F | f |
| Delta | D | d | Kappa | K | k | Pi | P | p | Chi | C | c |
| Epsilon | E | e | Lambda | L | l | Rho | R | r | Psi | Y | y |
| Zeta | Z | z | Mu | M | m | Sigma | S | s | Omega | W | w |
## C.2 Powers of 10 Unit Prefixes
| PREFIX | SYMBOL | MULTIPLYING FACTOR |
|---|---|---|
| tera | T | ×1012 |
| giga | G | ×109 |
| mega | M | ×106 |
| kilo | k | ×103 |
| centi | c | ×10-2 |
| milli | m | ×10-3 |
| micro | m | ×10-6 |
| nano | n | ×10-9 |
| pico | p | ×10-12 |
## C.3 Linear Functions ( y = mx + b )
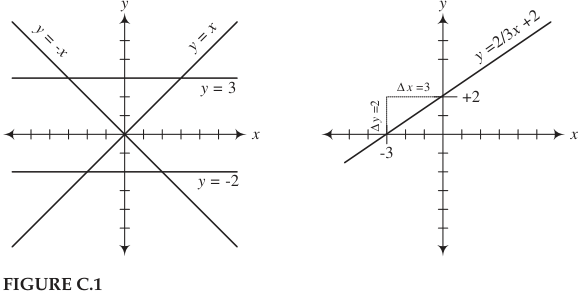
The equation y = mx + b represents the equation of a line. The slope of the line (D y /D x ) is equal to m , while the vertical shift, or point where the line crosses the y axis, is equal to b .
## C.4 Quadratic Equation ( y = ax2 + bx + c )
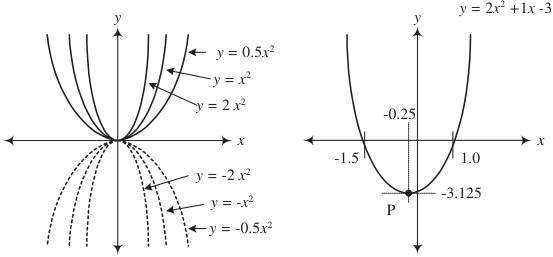
The equation y = ax2 + bx + c traces out a parabola in the xy plane. The narrowness of the parabola is influenced by a , the horizontal shift is given by - b /2 a , and the vertical shift is given by - b2 / a + c . To determine the roots of the equation (points where the parabola crosses the x axis), use
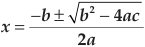
## C.5 Exponents and Logarithms
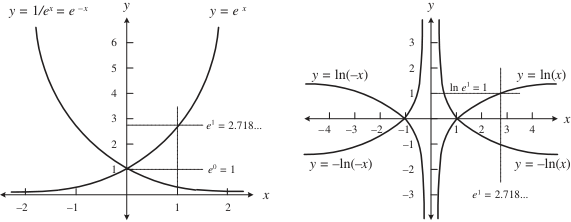
x0 = 1 Base 10: if 10n =
x, then log10 x = n 1/
xn = x n Base
e: if em = y, then ln
y = m x1/n = n
x (log10 100 = 2, since 102 = 100,
xm xn =
xm+n ln e = 1,
since e1 = e = 2.718 . . .) ( xy
)n = xn
yn Properties of any logarithm to the base
b: ( xn )m =
xn m log b 1 = 0 log
b b = 1 + b < 1 log b 0 = b >
1 log b ( x y ) = log b x + log b y
log b ( x/y ) = log b x log b y log
b ( xy ) = y log b
x
## C.6 Trigonometry
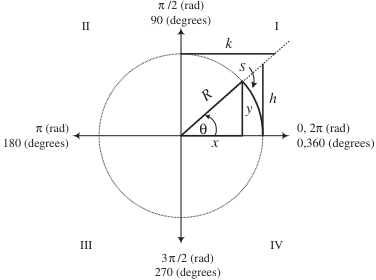
The angle p subtended by an arc S of a circle of radius R is equal to the ratio p = S / R , where p is in radians. 1 radian = 180°/π = 57.296°, while 1° = π/180° = 0.17453 radian. If R is rotated counterclockwise from the positive x axis, p is positive in sign. If R is rotated clockwise from the positive x axis, p is negative in sign. The trigonometric functions of the angle p are defined as specific ratios between the sides of the triangles shown in the figure and are expressed as
| sin θ = |
y R |
R if = |
y 1 → |
sin θ = |
|
|---|---|---|---|---|---|
| cos θ = |
x R |
R if = |
x 1 → |
cos θ = |
|
| tan θ = |
y x |
R if = |
h 1 → = |
tan θ |
|
| cot θ = |
x y = |
1 tan θ |
R if = |
k 1 → = |
cot θ |
| sec θ = |
R x = |
1 cos θ |
R if = |
x 1 1 → |
sec θ = |
| csc θ = |
R y = |
1 sin θ |
R if = |
y 1 1 → |
csc θ = |
Sine and Cosine Functions
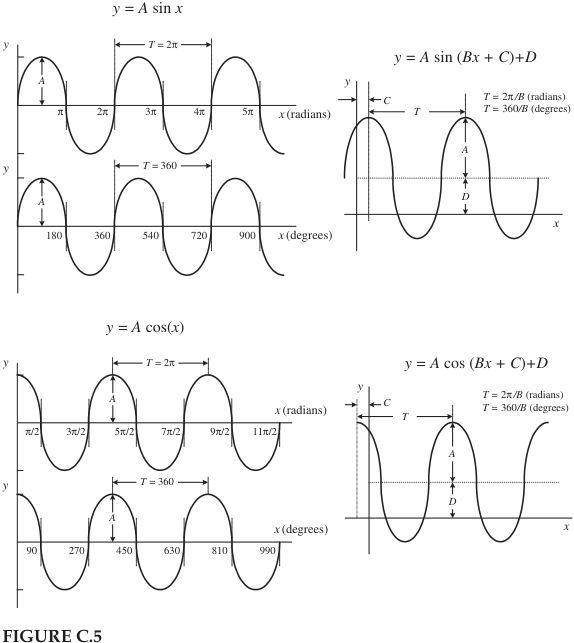
The graph of y = A sin p is shown to the far left. To alter the vertical, horizontal, period, and phase of this function, alter the equation to the form y = A sin ( Bx + C ) + D . A is amplitude, 2o/ B is the period ( T ), C is the phase shift, and D is the vertical shift. In electronics, a voltage can be expressed as
V ( t ) = V 0 sin (v t + e) + V dc
V 0 is the peak voltage, V dc is the dc offset, e is the phase shift, and v is the angular frequency (rad/s), which is related to the conventional frequency (cycles/s) by

The graph of y = A cos x is shifted in phase by π/2 radians (or 90°) with respect to the graph y = A sin x . The following relations show how the sine and cosine functions are related:
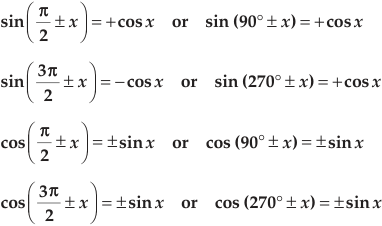
## C.7 Complex Numbers
Complex numbers are covered in detail in Chap. 2.
## C.8 Differential Calculus
Say you have a function f ( x ). This function may represent a line, parabola, exponential curve, trigonometric curve, etc. Now pretend that you take a point and move it along the curve of f ( x ). At the same time, you envision a tangent line touching the curve at the point. As the point moves along the curve, the slope of the tangent line changes (“teeter-totters”)—provided the curve is not a line. Now, the slope of the tangent line has great significance in real-life situations. For example, if you graph a curve of the position of an object versus time, the slope at a particular time along the curve represents the instantaneous velocity of the object. Likewise, if you have an electrical charge versus time graph, the slope at time t represents the instantaneous current-flow. Now, the trick to finding the slope of a tangent line for any point along a curve involves using differential calculus. What differential calculus does is this: If you have a function, say, y = x2 —through the tricks of differential calculus—you can find another function, which is called the derivative of y (usually expressed as y ′ or dy / dx ), that tells you the slope at every point along the curve of y . For y = x2 , the derivative is dy / dx = 2 x . If you are interested in the slope of y at x = 2, you plug 2 into dy / dx to give you a slope of 4. But how do you find the derivative of y = x2 ? Better yet, how do you find the derivative of any given function? The following provides the basic theory.
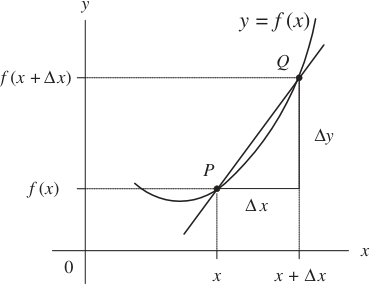
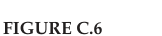
To find the derivative of a function y = f ( x ), you let P ( x , y ) be a point of the graph of y = f ( x ) and let Q ( x + D x , y + D y ) be another point of the graph. The slope of the line between P and Q is then simply
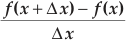
Now you substitute the function into the preceding equation. For example, if f ( x ) = x2 , then f ( x + D x ) = ( x + D x )2 , and the whole expression equals [(** x + D x )2 - x2 **]/D x . Next, you hold x fixed and let D x approach zero. If the slope approaches a value that depends only on x , you call this the slope of the curve at point P . The slope of the curve at P is itself a function of x , defined at every value of x at which the limit exists.You denote the slope by f ( x ) (“ f prime”), or dy / dx (“ dydx ”), or df / dx (“ dfdx ”), and call any one of these terms (your choice) the derivative of f ( x ):
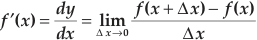
For the function f ( x ) = x2 , after carrying out the limit, you would get f ( x ) = dy / dx = 2 x as the derivative.
Now, in practice, if you need to find the derivative of a function, you do not bother using the preceding equation. To do so would be very time-consuming and might require a number of nasty mathematical tricks, especially if you are trying to find the derivative of a complex function such as 2 ex sin (3 x + 2). Instead, what you do is memorize a few simple rules and memorize a few simple derivatives. The table below shows some of the rules and simple derivatives that will come in handy for many applications. In the table, a and n are constants, while u and v are functions.
| DERIVATIVE | EXAMPLES |
|---|---|
| d dx a = 0 |
d dx = 4 0 |
| d dx x nx x n n n n = = − − (note: 1 x ) 1 |
d dx x d dx x x d dx x x d dx x = = = = − − − 1, 2 , 5 , x 2 5 4 1/2 12 3/2 |
| d dx e e x x = |
|
| d dx x x = ln 1 |
|
| d dx x x = sin cos |
|
| d dx x x = − cos sin |
|
| d dx au x a d dx u x = ( ) ( ) |
d dx x d dx x x d dx e e d dx x x x x = = = = 3 3 6 , 3 3 , 7sin 7cos 2 2 |
| d dx u v du dx dv dx + = + ( ) |
d dx x x d dx x d dx x x + = + = + (2 ) (2 ) ( ) 2 2 2 2 |
| d u v du dx u dv dx = − / / |
d x x x x x 2 2 2 1 1 2 1 2 + = − ⋅ − + ⋅ ( ) ( ) 4 = − x |
| dx v v 2 |
dx x x 2 2 1 1 − − ( ) 2 2 2 1 − x ( ) |
| Chain rule: If_u_is a function of_v_, and v_is in turn a function of_x, then |
|
| d dx u v x du dv dv dx ( [ ( )])= ⋅ |
d dx ax a ax d dx e e x x = = sin( ) cos( ), 2 2 2 |
## C.9 Integral Calculus
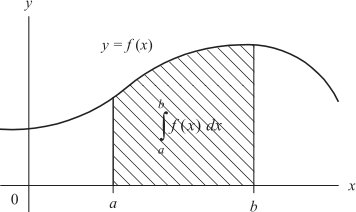
In differential calculus, our goal was to find the derivative of a function. In integral calculus, our goal is to find the functions of a derivative . In reality, calling one thing a derivative and another thing a function is somewhat confusing because a derivative is usually a function in itself. To avoid possible complications, we simply call anything that’s written as y = f ( x ) a function, call anything that’s written as dy / dx = df ( x )/ dx a derivative, and call anything that’s written as ∫ dy = ∫ f ( x ) dx an antiderivative or integral. In the last case, the “∫” is called the integral sign, the function f ( x ) is called the integrand, and dx is called the variable of integration. To integrate a function is to find all the functions that have it as a derivative—to find all of the given function’s antiderivatives. But, the term integration has a second, less technical meaning—to give the sum total of. In this meaning, integration represents a mathematical process that enables us to calculate the area of a region that has curved boundaries (see graph in Fig. C.7).
If we’re given an equation dy / dx = f ( x ) and wish to find y , we must integrate (antidifferentiate). In this case, we first rearrange the equation into the form dy = f ( x ) dx . Next, we integrate both sides:
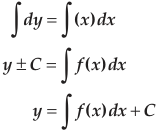
get y as the answer—we worked backward. Since C could be positive or negative, it’s arbitrary to give it a sign. This way, we simply add C to the left. In this form, we call the integral an indefinite integral.
Example: Given dy / dx = 2, find y .
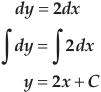
In real-life situations, it’s typically undesirable to have a constant in our answers, since we’re looking for a definite result. To get rid of the constant, we apply boundary conditions. For example, if we take our last example dy / dx = 2, we say we’re only interested in values of dy / dx from, say, 1 to 5—whatever range is appropriate for the situation. In that case, we take the definite integral
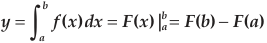
Without getting too technical, F represents the definite integral without the constant sign, while the ( a ) and ( b ) terms mean to place the boundary points into the x term of F . If we consider our example dy / dx = 2 with boundary condition 1 to 5, we’d get:
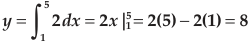
We call this a definite integral. At this point, it’s worth introducing a graphical approach to visualizing integration. If we consider dy / dx = 2, and graph dy / dx versus x , we get a straight horizontal line at dy / dx = 2 for all values of x . By summing up the area under the curve, we get the integral. So incorporating the boundary conditions the area is (5 - 1) × 2 = 8.
Now, if we attempt to integrate more complex functions, we’ll have a hard time guessing what the functions of the derivative are. Instead, we must apply some special tricks along the way. These tricks stem from a basic idea called the fundamental theorem of calculus , and they get fairly involved. Presenting the theory in such a short space isn’t going to do. However, in practice, you typically never use the fundamental theorem of calculus to find integrals of functions. Instead, you memorize a few fundamental integrals and learn a few tricks. The following list highlights some of the most common integrals and solutions. A mathematical handbook will provide a more extensive list. In the list, a u represents a function of x , while v represents another function of x .
dx = x + C ∫ a f ( x ) dx = a f ( x ) dx ∫ ∫ ( du ( x ) ± dv ( x )) = du ( x ) ± dv ( x ) ∫ ∫ ∫ udv = uv − vdu (integration by parts) ∫ ∫ un du = un +1 + C ( n ≠ 1) ∫ n + 1 1 ∫ udu = ln u + C e u dx = eu + C ∫ ln xdx = x ln x − x + C ∫ sin xdx = − cos x + C ∫ cos xdx = sin x + C ∫ x sin xdx = sin x − x cos x + C ∫ x cos xdx = cos x + x sin x + C ∫ sin x cos x = 12 sin 2 x + C ∫